Rasyid Fajar
RASYID FAJAR
AI Engineer Taipei, Taiwan · 25.03°N 121.56°E

RasyidFajar

I build deep-learning and computer-vision systems that run on real hardware and in real products: AI agents that keep my shrimp farm's pond log, 6DoF pose estimation on a robot arm, autonomous boats that won RoboBoat twice, and generative models for textile design.

robot_arm · time-lapse NYCU lab · 2024-01-29
cam_0 6DoF pose · auto-labeling rig
  • 1st ×2International RoboBoat Competition, Florida, 2018 and 2019
  • ~5×higher fabric upload rate after GAN texture-map prediction
  • 0.5–3 sper labeled 6DoF image from the robot-arm pipeline
  • 2IEEE papers on real-time human activity recognition
Selected work · 2018 – now

Projects

Aug 2026 – nowMy shrimp farm, IndonesiaIn daily use

Shrimpy: a pond log that fills itself from the workers' chat

The workers on my shrimp farm report in the group chat the way they always have: short messages in Javanese and Indonesian, plus photos of the feed trays. Haida Lab sends its water test results as PDFs. A capture bot stores every message. LLM agents read the chat and turn it into facts (feedings, treatments, water quality, harvests, stock), and Python checks each fact before it is written to Shrimpy, the farm's pond-tracking web app.

~20 minfrom a worker's message to the pond log, with nobody typing it twice
  • Six agents: lab reports, daily digest, tracker writes, reminders, tomorrow's feed plan, and expenses.
  • "The model chooses what, Python decides whether." Every write goes through a checked script, so a prompt can't break a rule like "no future dates".
  • Reads Haida Lab's PDF reports table by table (water quality, vibrio, plankton) and files each value under the right pond and sample date.
  • Understands farm slang through a glossary the farm maintains.
  • Posts feed plans and reminders to each pond's channel.
  • LLM agents
  • Claude
  • Python
  • Node.js
  • Baileys
  • SQLite
  • PostgreSQL
  • Next.js
Nov 2026 – nowMy shrimp farm, IndonesiaRunning on two ponds

Pond Vision: pan-tilt cameras that patrol the ponds

Two consumer pan-tilt cameras watch two ponds. Each one sweeps its pond into a 360° picture, then patrols a few viewpoints every 15 minutes, day and night. A detector finds every paddlewheel, pump outlet and check tray in each picture, and a status board shows what is there and where. Paddlewheels drift and pumps get carried off, so nothing is assumed to stay in a fixed box.

2,689patrol pictures kept for labeling in the first week
  • One control layer for two camera brands: move, presets, snapshots and a frame stream, through a cloud relay for one and a local decoder for the other.
  • Places each patrol picture on the pond's 360° by feature matching, to within about 2 px, so every object keeps its own angle.
  • A labeling page where you click points and draw boxes; labels carry over to the next pictures by template matching.
  • D-FINE detector trained on Kaggle, run with ONNX Runtime on the CPU of a 3.8 GB server.
  • Only Apache, MIT and BSD models and libraries, so the system can be sold later.
  • Python
  • OpenCV
  • D-FINE
  • ONNX Runtime
  • FastAPI
  • SQLite
  • Cloudflare R2
  • Kaggle
repeat detected · 72 × 72 px
Jun 2024 – nowFrontier.cool, Taipei

AI for digital fabric: generation, texture maps and pattern repeats

Solutions for fabric image generation, image-to-image translation, image–text retrieval and chatbots, mixing classic algorithms with deep learning for problems specific to textiles.

  • Fine-tuned Stable Diffusion 1.5 with LoRA in Hugging Face Diffusers to generate fabric images, for a multi-million NTD project.
  • Improved normal and displacement map prediction with a GAN in PyTorch.
  • Built repeating-motif detection, a palette-based color editor and a woven-fabric yarn counter with NumPy, SciPy and OpenCV, cutting manual correction for designers.
  • Building agentic AI with LangChain and Google Gemini.
~5×upload rate after the texture-map model shipped
  • PyTorch
  • Diffusers
  • LoRA
  • GAN
  • OpenCV
  • SciPy
  • LangChain
  • Gemini
6DoF · CAD alignment
Sep 2023 – May 2024NYCU, Hsinchu

Robot-arm 6DoF pose estimation and auto-labeling

Object manipulation with a camera and a robot arm. I implemented a 6DoF pose estimation model that aligns RGB images to the part's CAD model, for automated optical inspection. I also designed a labeling pipeline where the arm moves the camera and records a labeled image every 0.5 to 3 seconds.

  • PyTorch
  • 6DoF pose
  • CAD model
  • Robot arm
  • AOI
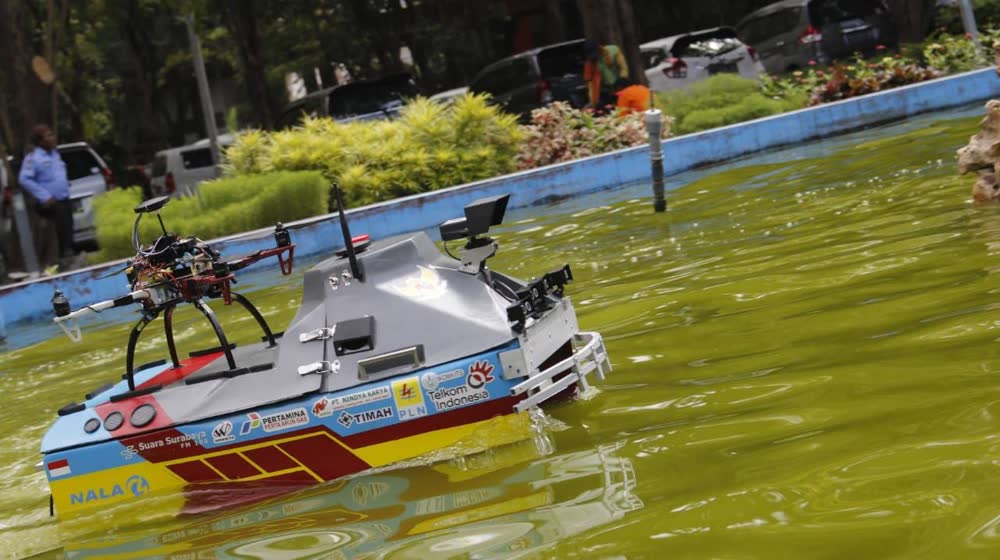
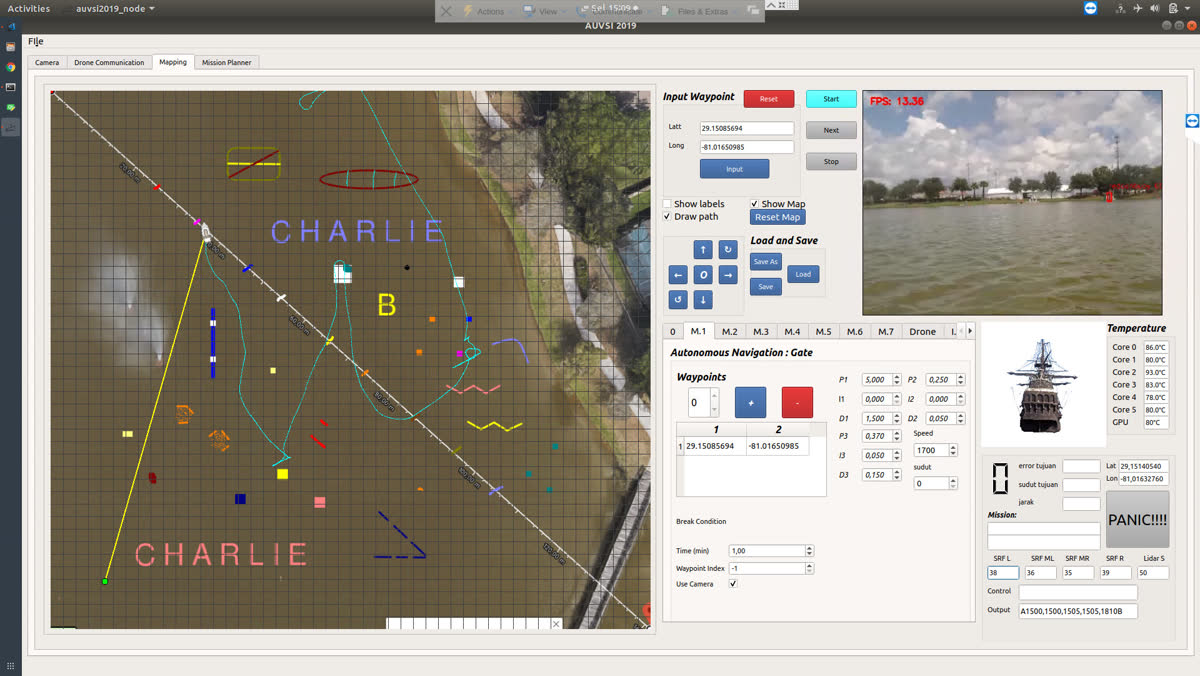
Team Barunastra ITS autonomous surface vehicle with a drone on its deck, on the water Ground control software showing waypoints, buoys and the boat camera feed
2019Team Barunastra ITS1st place

RoboBoat 2019: Nala Destroyer

An autonomous surface vehicle for four tasks: speed gates around a mark buoy, finding an underwater acoustic pinger, working with a drone to read a 7-segment number and press the matching button, and planning a path through an obstacle field around a can buoy.

  • C++
  • Python
  • TensorFlow
  • Object detection
  • LiDAR
  • GPS navigation
  • MAVLink
  • Motion control
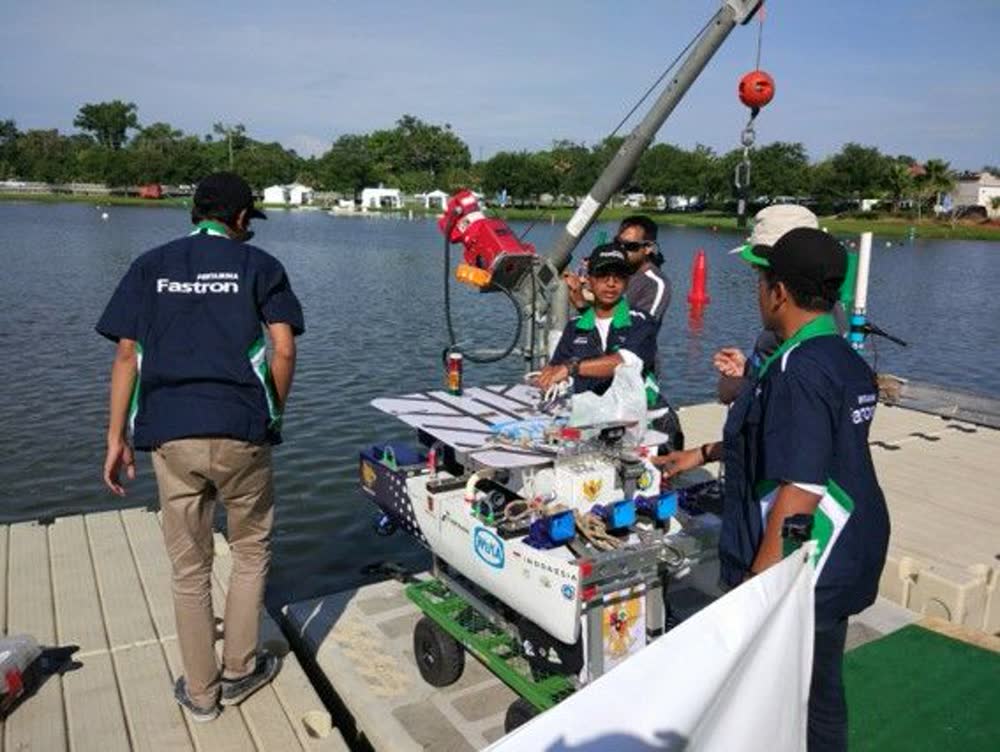
Team members launching the 2018 boat from a floating dock
2018Team Barunastra ITS1st place

RoboBoat 2018: Nala Heroes

Same competition, different course: speed gates, acoustic docking, and following a flag on a moving carousel for a full 360° at a constant distance without touching it, plus the obstacle-field path. Control code in C++, operator interface in Qt.

  • C++
  • Qt
  • Image processing
  • GPS navigation
  • Motion control
Cover page of the NTUST master's thesis on real-time action recognition for cleanroom procedures
2023NTUST · MBA thesis

Real-time action recognition for cleanroom SOP

A lightweight system that checks whether people follow the standard operating procedure in a cleanroom. It runs in real time on ordinary PCs without a GPU, which keeps hardware cost and compatibility manageable on the factory floor.

  • PyTorch
  • MoViNet-A0
  • YOLOX-Tiny
  • IoU tracking
  • 3D CNN
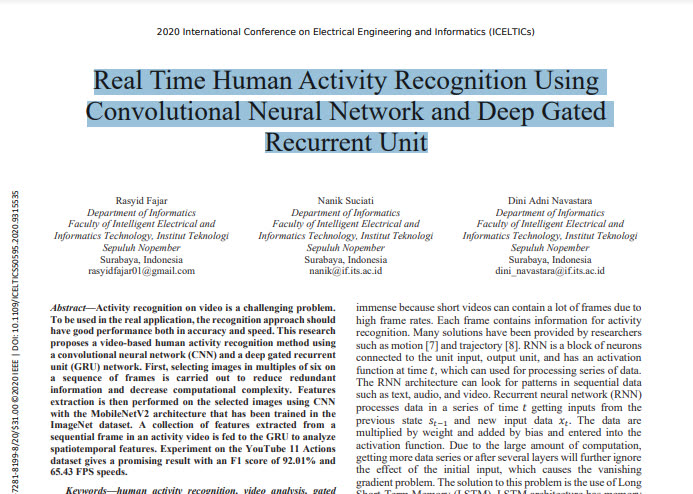
First page of the ICELTICs 2020 paper on human activity recognition with CNN and GRU
2020ITS · Bachelor thesis

Real-time human activity recognition with CNN and GRU

Real-time video classification on the YouTube-11 action dataset, with MobileNetV2 extracting per-frame features and a GRU modelling them over time.

  • TensorFlow
  • MobileNetV2
  • GRU
  • OpenCV
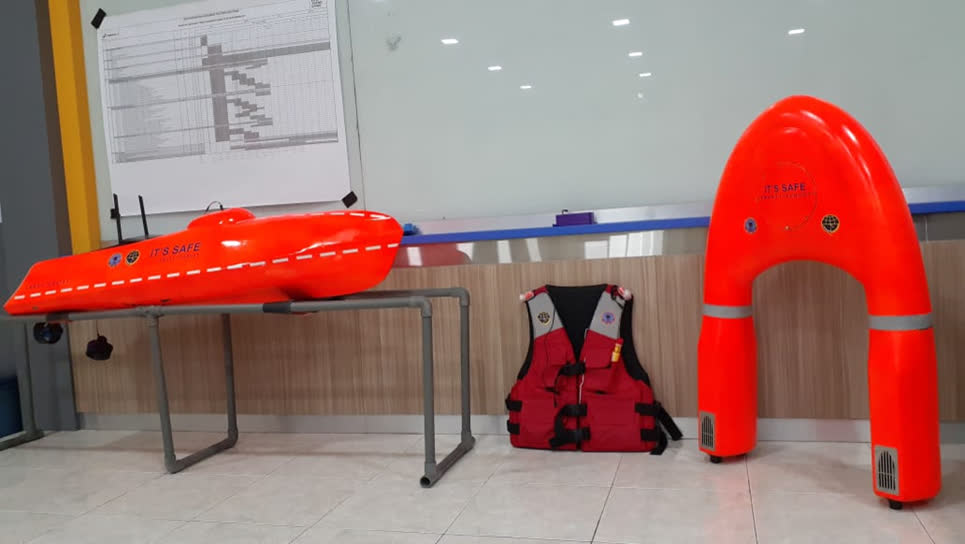
Orange autonomous lifeboat hull, a lifejacket and a rescue buoy in the lab
PrototypeMaritime rescue

Autonomous lifeboat

A lifeboat that picks up people in the water. Each lifejacket sends its latitude and longitude over Wi-Fi; the boat drives to them, and when it is full it finds the nearest shore with A* and heads there. Tested in simulated rescue scenarios.

  • Raspberry Pi
  • ESP32
  • Python
  • A*
  • PyQt
  • Sockets
Where I've worked

Experience

Jun 2024 – now

Frontier.cool

AI Engineer · Taipei
  • Fabric image generation with a LoRA fine-tuned Stable Diffusion 1.5.
  • GAN for normal and displacement maps; upload rate up about 5×.
  • Pattern-repeat detection, palette color editor and yarn counter in OpenCV.
  • Agentic AI with LangChain and Gemini.
Sep 2023 – May 2024

National Yang Ming Chiao Tung University

Research Assistant · Hsinchu
  • Object manipulation with a camera and a robot arm.
  • 6DoF pose estimation from RGB and CAD alignment in PyTorch, for optical inspection.
  • Automated 6DoF labeling rig: one labeled image every 0.5–3 s.
Degrees and papers

Education

Feb 2021 – Feb 2023

National Taiwan University of Science and Technology

MBA, Industrial Management · Taipei
Aug 2016 – Oct 2020

Institut Teknologi Sepuluh Nopember

B.S. Computer Science, Informatics · Surabaya
Toolbox

Skills

Languages

Python, C++, C

AI frameworks

PyTorch, TensorFlow, OpenCV, Hugging Face, LangChain

Robotics

ROS basics, GPS navigation, MAVLink, motion control

Tools

Git, Docker

Contact

Have a robot that needs eyes?